
Beschreibung
UNITREE BrainCo Revo 2 Touch Robotic Hand
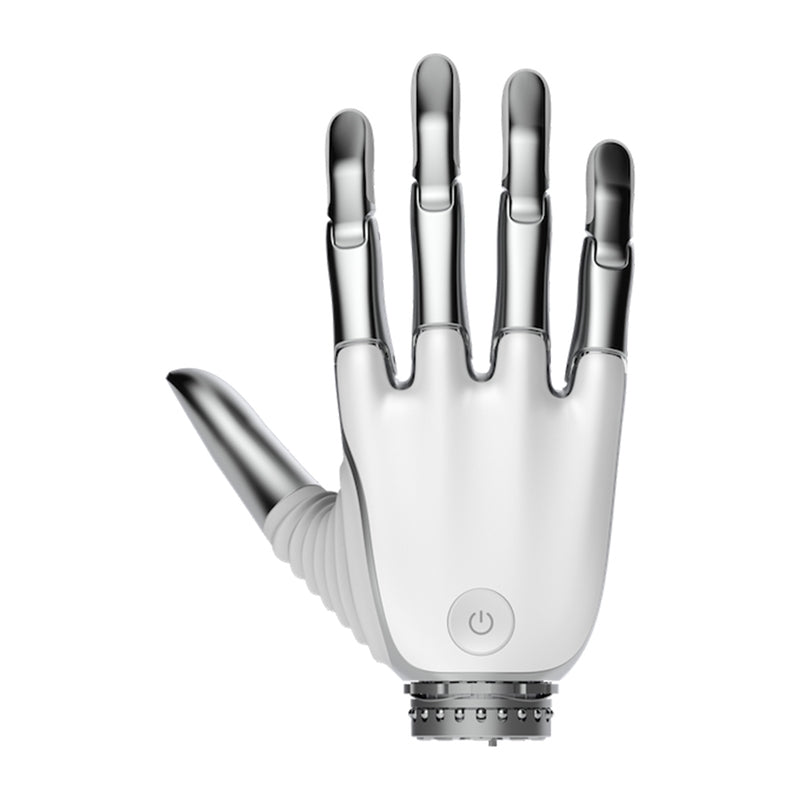
The BrainCo Revo 2 Touch is an advanced robotic hand designed for integration with Unitree humanoid robots. The design offers 11 degrees of freedom, including 6 actively driven joints, allowing for complex movements and precise manipulation of objects. The Touch version is additionally equipped with a tactile module and Tactile Adaptive Control, which expands its capabilities for interacting with the environment. With a maximum grip force of up to 50 N, a payload capacity of approximately 20 kg, and support for RS485, CAN FD, and EtherCAT interfaces, this model is ideal for both research work and advanced robotic projects.

Biomimetic design that mimics the movements of the human hand
The Revo 2 Touch model was designed to replicate the functioning of the human hand as faithfully as possible. The design features 6 active joints and as many as 11 degrees of freedom. The thumb has two active degrees of freedom and an additional passive degree of freedom, which increases the range of possible movements. The other fingers also mimic natural movement, allowing the robot to perform complex gestures and effectively manipulate various objects.

Touch sensors for even greater precision
The Touch version is equipped with a multidimensional touch module located on the fingertips. This enables the hand to detect contact with objects and gather additional information about the operations being performed. This solution improves manipulation accuracy and facilitates tasks requiring greater precision when grasping and handling objects. Additionally, the Tactile Adaptive Control feature is available. All of this allows for more effective and safer handling of components with various shapes, sizes, and properties.

High grip force in a lightweight design
Despite weighing just 383 g, the Revo 2 Touch offers a full-grip force of up to 50 N and a pincer grip force of 15 N. The maximum payload reaches 20 kg, which further expands the range of possible applications. An additional advantage is the maximum opening distance of 100 mm between the thumb and index finger, which allows for comfortable manipulation of objects of various sizes.

Fast and smooth operation
The hand has been optimized for dynamic operation. The time required for full flexion or extension is no more than 0.65 s, enabling efficient execution of successive operations. Combined with high control precision of 0.1°, this results in smooth and repeatable execution of various movements.

Easy integration with robotic systems
The Revo 2 Touch model supports RS485, CAN FD, and EtherCAT communication interfaces, allowing it to be integrated with a wide range of robotic platforms and control systems. This solution facilitates the deployment of the robotic hand in both new and existing research or industrial environments. Additionally, the manufacturer provides an SDK compatible with Python and C. This allows users to easily create their own applications, integrate the device into existing projects, and develop advanced control functions tailored to specific applications.

Advanced control modes
The gripper supports position, speed, and current control, as well as cascade and compliance control. The available operating modes allow, among other things, reaching a set position within a specified time, operating with speed limits, or maintaining specified current parameters. All of this allows you to precisely tailor the device’s operation to current requirements. Added to this is the Turbo function, which utilizes a motion-block detection mechanism. Upon contact with an object, the hand can continue to tighten its grip at specified intervals (every 500 ms), which is particularly useful when working with soft or easily deformable objects. This solution helps maintain a stable grip even in more demanding scenarios.

Define Your Own Gestures and Action Scenarios
Revo 2 Touch allows you to create your own gestures and motion configurations. This enables you to prepare sequences of actions tailored to specific processes or tasks performed by the robot. This solution increases implementation flexibility and facilitates the automation of repetitive operations.

Safe and Reliable Operation
The device is equipped with safeguards against current overload, mechanism lockup, overheating, and collisions. Additionally, it supports OTA updates, which allow for the convenient implementation of new features and improvements without the need for physical intervention on the hardware. As a result, the hand can be continuously developed and adapted to new applications.

| Manufacturer | BrainCo |
|---|---|
| Model | Revo 2 Touch |
| Version Code | XTL / XTR |
| Type | Biomimetic robotic hand |
| Number of degrees of freedom | 11 |
| Number of active degrees of freedom | 6 |
| Weight | 383 g |
| Hand height | 160 mm |
| Maximum hand width | 78.5 mm |
| Thumb length | 92 mm |
| Wrist diameter | 38 mm |
| Wrist height | 13.5 mm |
| Full-grip force | ≥50 N |
| Pincer grip force | ≥15 N |
| Maximum payload | ≥20 kg |
| Noise level (at a distance of 50 cm) | ≤50 dB |
| Bending/straightening time | ≤0.65 s |
| Maximum opening distance | 100 mm (between thumb and index finger) |
| Communication interfaces | RS485, CAN FD, EtherCAT |
| Supply voltage | 12–64 V |
| Quiescent current | 115 mA at 24 V |
| Average no-load current | 390 mA at 24 V |
| Maximum current | 4.65 A at 24 V |
| Control repeatability | 0.1° |
| Operating temperature | From -10°C to 40°C |
| Maximum operating humidity | 90% RH |
| Touch Module | Multi-dimensional fingertip touch module |
| Intelligent Control | Position control, speed control, current control, cascade control, compliance control, Tactile Adaptive Control |
| Safety Features | Overcurrent protection, stall protection, overheat protection, anti-collision protection |
| SDK Integration | Supported programming languages: Python, C Supported operating systems: Linux, Windows, ROS |
| Updates | OTA |
| Thumb range of motion (flexion/extension) | 0°–59° |
| Thumb range of motion (adduction/abduction) | 0°–90° |
| Index finger range of motion | 0°–81° |
| Range of motion of the middle finger | 0°–81° |
| Range of motion of the ring finger | 0°–81° |
| Range of motion of the little finger | 0°–81° |
| RS485 connector | A1257WV-S-2P-6T |
| CAN FD connector | A1257WV-S-2P-6T |
| EtherCAT connector | A1257WV-S-5P-6T |
| Power connector | XT30UPB-M |
Producer: Hangzhou Yushu Technology Co., Ltd. (CN)
Address: Fengda Creative Park, 88, 310051, Hangzhou
Email: sales_global@unitree.cc
EU Responsible Person: INNPRO Robert Błędowski sp. z o. o.
Address: Rudzka, 65C, 44-200, Rybnik
Email: zgloszenia@innpro.pl
Das könnte Ihnen auch gefallen
Zuletzt angesehen
Sichere Zahlung auf unserer Website